

CiMMS
CiMMS 3D
Condition Inventory Maintenance and Management System (CiMMS) has been developed by SOWiL Limited as a comprehensive system to collect road asset and pavement information. CiMMS 3D is a patented Network Survey System that covers automatic data acquisition, automatic data processing, and automatic report generation.
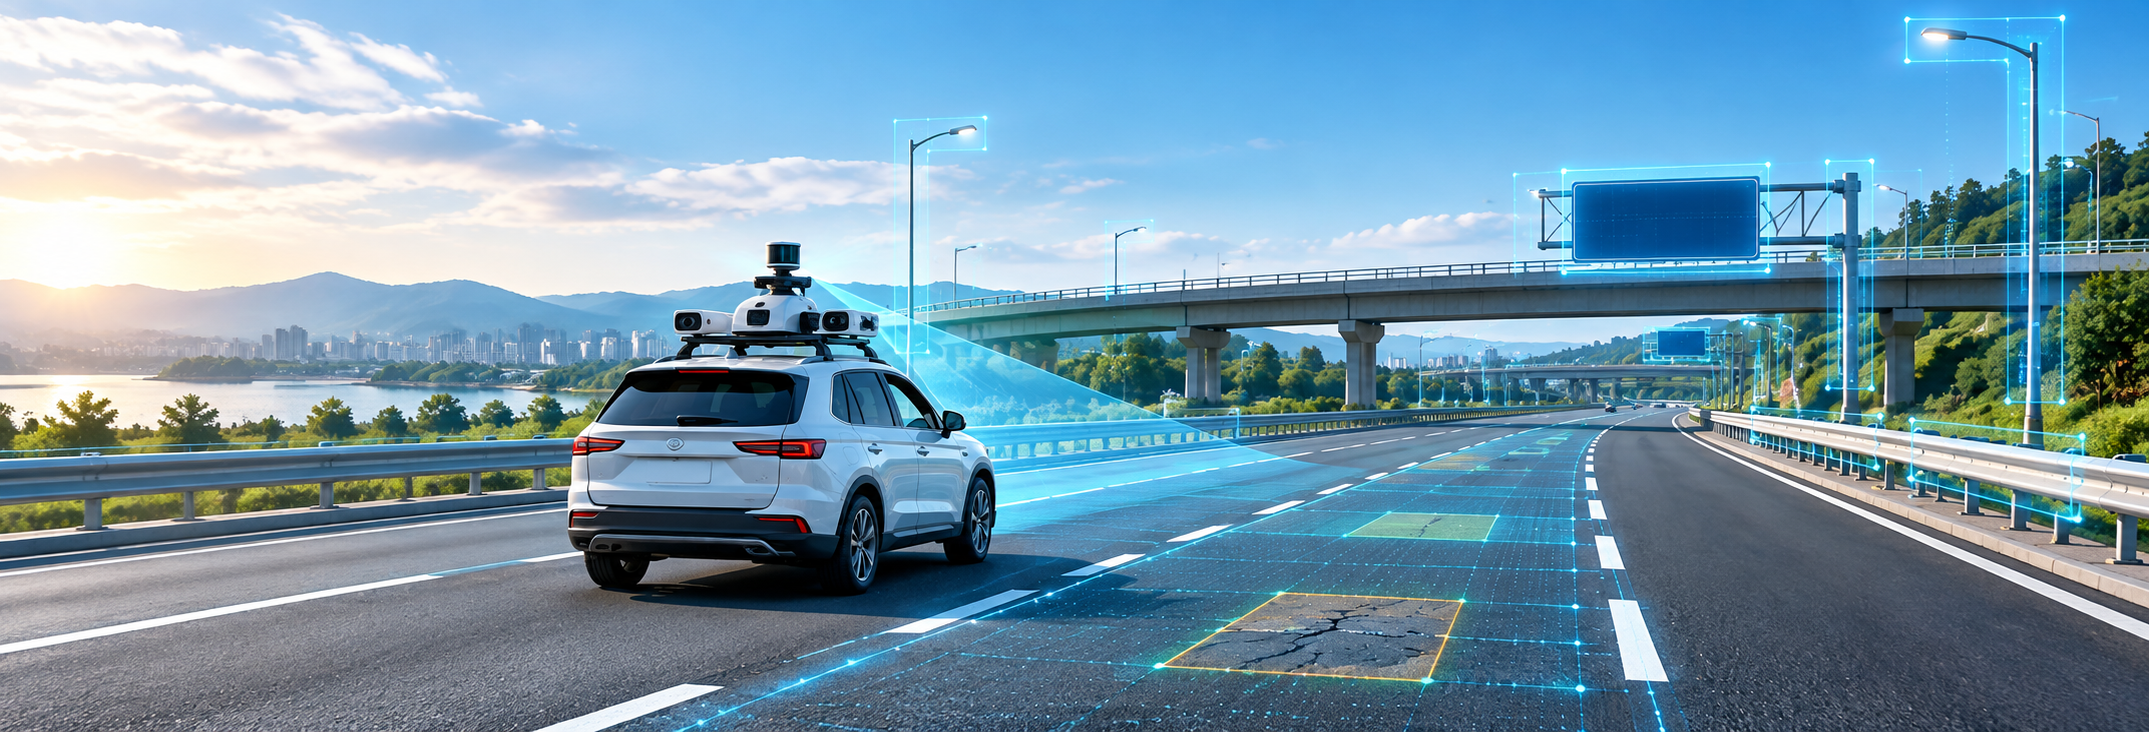
The Network Survey Vehicle uses Differential Global Positioning System (DGPS), a 3D laser-cum-camera system, and high-quality video cameras. It collects road inventory and pavement condition data for pavement maintenance management, road safety audit studies, and road asset management. The cameras capture 180-degree and 360-degree views.
Download CiMMS Presentation (PDF)
Network Survey Vehicle
The survey vehicle carries the sensors and computers used to collect, store, and begin processing inventory and pavement data while the survey is underway.
Hardware
- 180-degree and 360-degree GPS-enabled cameras, and a rear GPS-enabled camera
- 3D laser-cum-camera (PG4)
- DGPS and an inertial measurement unit (IMU) with GPS
- Distance measuring instrument (DMI) and encoder
- LPS-P IRI system with DGPS
- On-board computer system for data collection, vehicle tracking, and an analysis computer
The 180-degree and 360-degree cameras record at up to 5.7K in H.264, store video on a MicroSD card, and include Wi-Fi and built-in GPS. The rear 2D camera records at up to 4K with the same video format, storage, Wi-Fi, and GPS. The DGPS receiver is a multi-frequency, multi-GNSS RTK unit covering GPS, GLONASS, BeiDou, and Atlas.
The PG4 3D laser-cum-camera is mounted on the vehicle and collects 3D pavement data together with high-definition images used to identify cracks and rutting. It can capture crack inspection data at a 4 mm pitch while travelling at 100 km/h, without closing lanes. Survey speed is up to 100 km/h, with 1 mm/pixel transversal resolution, 0.5 mm height resolution, and 1 mm to 4 mm longitudinal resolution. Its software supports lane-mark detection, 2D and 3D viewing, GPS linking, mesh processing, and automatic or manual analysis of rutting, cracks, and potholes.
The distance measuring instrument uses a non-contact laser Doppler system, so measurement is not affected by wheel slip, idling, or abrasion. It measures velocity and travel distance from a stop, including in rain or on an uneven surface. The inertial measurement unit combines accelerometers, gyroscopes, and magnetometers to determine vehicle position and orientation.
Inside the vehicle, the installation includes the laser power supply, power box, encoder box, control PC, and display monitor. The LPS-P dual longitudinal laser profiler measures International Roughness Index (IRI), standard deviation, and Riding Quality Index (RQI) along both wheel paths. It operates from 25 km/h to 120 km/h and processes data automatically at 100 metre or 1 kilometre intervals.
Software
- CiMMS File Uploader
- CiMMS Inventory Collector
- CiMMS IRI Collector and Analyzer
- Kurabo CiMMS Pavement Analyzer
- CiMMS Integrator
- CiMMS Report Maker
- CiMMS Viewer
Road Inventory Data Acquisition
Front and middle cameras record roadside furniture and road assets. Built-in GPS geo-tags each video, and the system also stores a date-time stamp, the road track, and elevation with the imagery. The 180-degree camera provides a wide field of view around its mounting point. The 360-degree camera records every angle of the road, its assets, and its surroundings.
- A front 180-degree camera and a central 360-degree camera record roadside furniture and other road assets.
- Each video frame is geo-tagged for spatial analysis and asset management.
- Date, time, and road track are stored with every frame.
Pavement Condition Data Acquisition
The 3D camera system works with DGPS to evaluate the road surface. High-definition, high-speed imaging and an infrared laser support continuous inspection. The pavement condition analysis module produces a single dataset covering DGPS-based pavement images, rutting, cross slope, crack detection and depth, potholes, sensor-measured texture depth, and IRI.
Collected pavement parameters include:
- Transverse profile, rut depth, crack metrics, and sealed-crack assessment
- Ravelling, patch condition, potholes, edge break, and concrete condition
- Road geometry, macro and micro texture, lane marking, and defect depth
- Mean Profile Depth (MPD) and Mean Texture Depth (MTD) for skid resistance across the five AASHTO bands
- Roughness and rutting
The LPS-P laser profiler measures highway roughness and supports acceptance measurements of road surface roughness. It displays IRI, standard deviation, and RQI in real time.
Data Processing System
CiMMS File Uploader
The File Uploader sends inventory and pavement data from the survey site. It uploads in small segments, so transfer continues on a weak connection and resumes from the last point if the connection drops. The analysis team can receive data before the survey vehicle returns and without waiting for a portable drive, which reduces transport time.
CiMMS Inventory Collector
The Inventory Collector uses artificial intelligence to detect, mark, and interpret roadside objects. Recognition of assets is automatic, so the survey does not depend on manual marking.
CiMMS Integrator
The Integrator brings together outputs from FWD, IRI, rutting, sensor-measured texture depth (SMTD), and mean texture depth (MTD). Analysts and engineers work from one combined view of these sources.
Road Inventory Analysis Module
The module records roadside assets together with time, GPS position, inventory type, and name. The Inventory Collector processes video with AI, detects and marks objects, and stores each asset with its detection time and coordinates. Plan and profile views show the position of each item. Matched records are shown in green and unmatched records in orange. Filters and auto play step through the data. The same view supports an as-built audit against the plan profile and the detailed design drawing.
Inventory is stored in a defined hierarchy. The types and subtypes covered include:
Roadside utilities
Electric pole, telegraphic pole, HT line, HT tower, well, hand pump, gas pipeline, water pipeline, other cables, LT line, high mast light, and CCTV pole.
Land use
Residential, agricultural, commercial, forest, barren, religious place, institutional bodies, and government office.
Trees and plantations
Trees, bushes, shrubs, and other plantations.
Wayside amenities
Bus stand, lay-bys, rest area, petrol pump, hotel, motel, restaurant, and vehicle service point.
Junctions and structures
At-grade, grade-separated, and oblique junctions, T, Y, and right-angle junctions, flyover, vehicular underpass, pedestrian underpass, cattle pass, single and double trumpet, clover leaf, hairpin bend, four-arm junction, and village road.
Cross-drainage works
HP culvert, Armco culvert, box culvert, slab culvert, minor and major bridges (single and multi span), and canal crossing.
Water bodies
Pond, lake, canal, river, streams, and tubewell.
Pavement, shoulder, and slope
Shoulder cuts, drop, and uneven shoulders; bituminous, gravel, earthen, and concrete pavement; divided road; cracking, raveling, potholes, rutting, and damaged pavement; paved and unpaved shoulders; hill side, valley side, incline, decline, retaining wall, and breast wall.
Signs and toll
Overhead gantry sign board, roadside sign board, notice board, milestone, and toll gate.
Pavement Condition Analysis Module
This module takes DGPS-based 3D pavement crack data, pavement video, rut profiler data (including cross slope), IRI, sensor-measured texture depth, and FWD output, then syncs and integrates them automatically. Laser scanning, machine learning, and computer vision detect cracks and measure length, width, and depth in three dimensions, including 2D and 3D views of cracks, potholes, and rutting.
The software detects and analyses:
- Crack measurement (length, width, and depth), sealed crack area, raveling, and patch area
- Potholes, including dimensions and depth, and edge break
- Concrete condition, road geometry, texture, roughness, and rutting
- Lane marking, depth measurement, and transverse profile
Rut data is captured for the left wheel path and the right wheel path. Pavement records are stored with video, time, GPS position, type, and name.
Pavement classification covers flexible and rigid pavement, and surface types of bituminous, brick, concrete, cobblestone, and asphalt. Crack types include alligator, longitudinal, and transverse cracking.
Report Viewer System
CiMMS Viewer is the report dashboard. It includes Plan Profile Comparison, the Road Inventory System, the Pavement Information System, and the Traffic Information System.
Captured inventory is shown with its image and in step with Google Map navigation. Measurements, such as the height of a pole, appear with the asset, and the map marks its position. Filters select records by inventory name, and auto play steps through the data. The same interface compares the proposed plan with the current condition of the road assets: matched rows are shown in green and unmatched rows in orange.
Presentation
The full CiMMS 3D presentation, including the network survey vehicle, hardware and software, inventory and pavement modules, and the report viewer, is available as a PDF.